- ISO 6336
- AGMA 2001-D04
- DIN 3990
Precision Gear Design. ISO 6336 Native.
Calculated to standard.
Desktop software for spur and helical gear design. Full ISO 6336 strength rating. Designed by the engineer who signs the inspection report.
TECHNICAL FOUNDATION
ISO 6336
Pitting resistance Tooth bending strength
AGMA 2001
Comparative output on every calculation
10⁻⁴ mm
Metric precision GUM uncertainty model
DIN 3990
Reference standard normative context
PyQt6 desktop
Windows · Linux
60 Hz live mesh
Real-time kinematics
Local execution
Activation via secure server
Validated
Against normative examples
Spur · Helical
Cylindrical gears
The problem with current tools
KISSsoft costs €12,000/year.
Excel has no normative backbone.
There was no middle ground.
Individual mechanical engineers and consultants are priced out of enterprise software — and forced to rely on spreadsheets with no normative context. One wrong $K_A$ propagates silently through every result.
Cost barrier
KISSsoft, MASTA, and Romax are priced for OEM procurement budgets — €12,000 to €40,000 per seat per year. An independent engineer or small consultancy cannot justify that cost.
€12k+/year → out of reach
No normative rigor
Spreadsheets carry no normative context object. A single incorrect $K_A$ or $Z_E$ propagates silently through every downstream result — with no audit trail and no standard to reference.
Silent errors → no audit trail
Iteration speed
Manual ISO 6336 iteration — adjusting x₁, x₂, β, $K_A$ across a full factor chain — takes hours per design cycle. QEVORK closes the loop in seconds, with full coefficient visibility.
Hours of iteration → seconds
$59/mo after trial · Cancel anytime
What Qevork does
Every calculation. Every factor. No shortcuts.
From basic geometry to full ISO 6336 strength rating and real-time mesh kinematics — in a single desktop application.
Full ISO 6336 geometry
$m_n$
z
β
x
$α_n$
$ε_α$
d
$d_a$
$d_b$
$d_f$
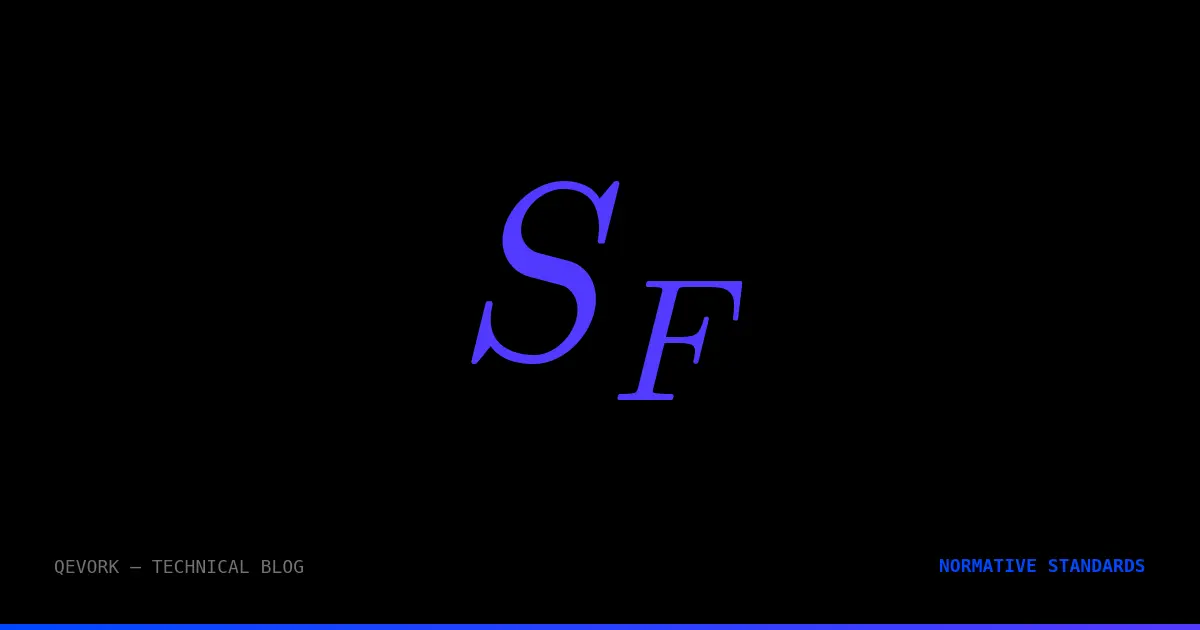
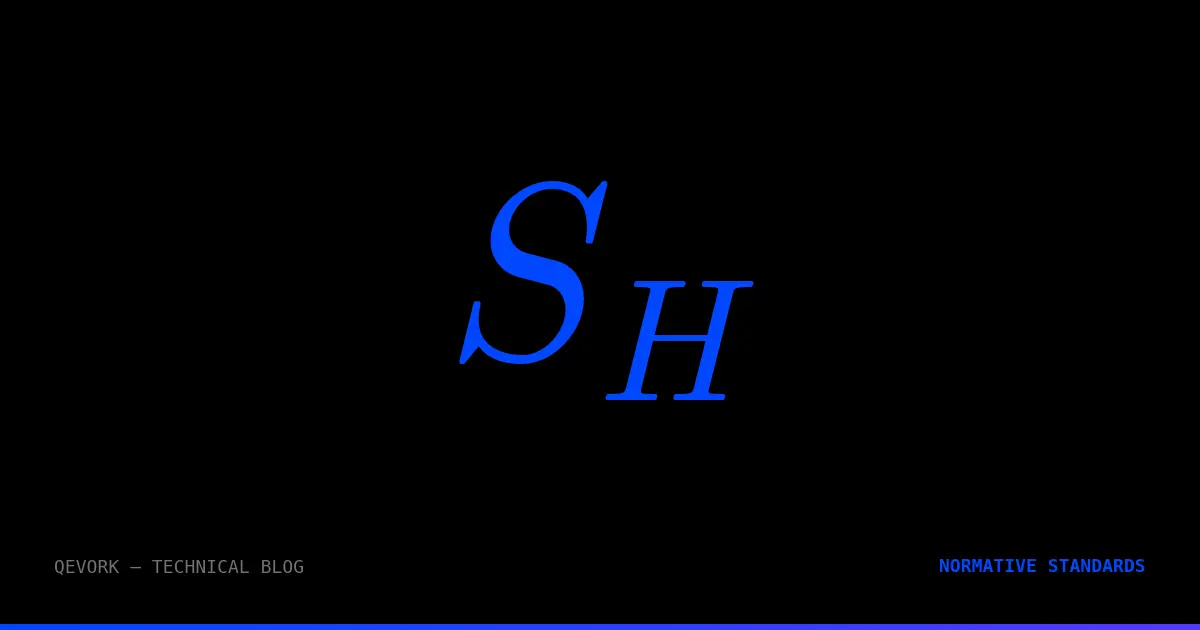
$S_H$ and $S_F$ strength rating
$Z_H$
$Z_E$
$Z_ε$
$Z_β$
$K_A$
$K_v$
$K_Hβ$
$K_Hα$
60 Hz real-time mesh visualization
Involute
Contact patch
Hob simulation
$f_Hα$ · $f_Hβ$
AGMA 2001-D04 comparative report
$Z_W$ · $C_H$
$Y_J$ · J
$S_H$ · $S_F$
PDF export
TCA and Transmission Error analysis
TCA 3D
TE spectrum
$K_Hβ$ loaded
Edge load factor
Profile shift optimizer and CAD export
x₁ · x₂
Ca · Cf · Cβ
STEP · IGES
DXF · PDF
How It Works
STEP 01
Download
Install the desktop app.
STEP 02
Input gear data
$m_n$, z, β, x, material, $K_a$.
STEP 03
Calculate
Full ISO 6336 strength.
Instant results.
STEP 04
Visualize
Tooth profile, hobbing plot, safety factors.
Three tiers. Zero overlap. Priced to the physics you need.
METROLOGY
Single-gear geometry, simplified strength analysis, dimensional tolerancing, reverse engineering via CMM, and manufacturing data sheet — the complete deterministic foundation for anyone measuring and specifying an isolated gear.
- Single gear calculation
- Spur + helical gears
- ISO 6336 simplified strength
- Manufacturing data sheet (dimensions over pins/balls, span measurement)
- ISO 1328-1 tolerance grading
US$59
/mo
US$ 708 / year
DESIGN
Everything in T1 + gear pair, helical gears, full ISO 6336, micropitting, wear, power loss/efficiency, multi-stage gearbox, PDF report, and technical drawing — the complete design engine.
- Everything in METROLOGY
- Mating pair calculation
- ISO 6336 full strength analysis
- AGMA 2001-D04 comparative report
- PDF report
US$249
/mo
US$ 2.490 / year
2 months free
Coming soon
DYNAMICS
Everything in T2 + real-time multibody dynamic simulation, 3D loaded TCA, transmission error, tip relief, Campbell diagram, and numerical/2D export — the only tier with dynamic contact physics.
- Everything in DESIGN
- TCA + TE
- Tip Relief optimizer
- Mating pair
- STEP / DXF / JSON
US$499
/mo
US$ 4.990 / year
2 months free
Coming soon
Payment can be made in up to 12 installments.
From the builder
BUILT BY A PRACTITIONER
"I designed gears professionally and inspected them to ISO standards. I built Qevork because the tools available were either too expensive or too imprecise. Every calculation in this software is validated against normative examples."